DynamicReliefValve#
Copyright © EDF 2002 - 2026#
ThermoSysPro Version 4.2#
This component model is documented in Sect. 13.13 of the ThermoSysPro book.
Dynamic relief valve#
Relief valves are used to limit the pressure in a system.
When the set pressure level is exceeded, the relief valve opens.
It closes again once the system pressure reaches the valve reseting pressure.s
Following assumptions are made:
the fluid is subsonic and incompressible.
the volume inside the valve is negligible, so that inertia is neglected.
Modelica component model#
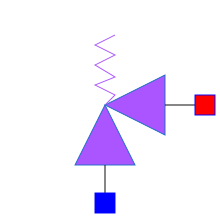
The equations mentioned below are implemented in the component DynamicReliefValve, located in the WaterSteam.PressureLosses sub-library.
This component has 2 connectors:
C1: fluid inlet,
C2: fluid outlet.
Nomenclature#
Symbol |
Description |
Unit |
Definition |
Modelica name |
|---|---|---|---|---|
\(A_{\mathrm{i}}\) |
Clapper section at the inlet |
\(\mathrm{m}^{2}\) |
A |
|
\(A_{\mathrm{o}}\) |
Clapper section at the outlet |
\(\mathrm{m}^{2}\) |
A2 |
|
\(C_{\mathrm{v}}\) |
Flow coefficient of the valve |
U.S. [USG/min] |
Cvmax |
|
\(D\) |
Valve damping |
\(-\) |
D |
|
\(f_{\mathrm{d}}\) |
Force acting on the clapper due to damping |
\(\mathrm{N}\) |
Fd |
|
\(f_{\mathrm{h}}\) |
Hydraulic force acting on the clapper |
\(\mathrm{N}\) |
Fh |
|
\(f_{\mathrm{s}}\) |
Force acting on the clapper due to the spring |
\(\mathrm{N}\) |
Fr |
|
\(f_{\mathrm{t}}\) |
Total force acting on the clapper |
\(\mathrm{N}\) |
Ft |
|
\(f_{\mathrm{w}}\) |
Force acting on the clapper due to the weight of the clapper |
\(\mathrm{N}\) |
Fp |
|
\(h\) |
Fluid specific enthalpy |
\(\mathrm{J} / \mathrm{kg}\) |
h |
|
\(h_{\mathrm{c}}\) |
Valve height |
\(\mathrm{m}\) |
\(h_{\mathrm{c}}=z_{\max }-z_{\min }\) |
- |
\(K_{\mathrm{e}}\) |
Valve spring stiffness |
\(\mathrm{N} / \mathrm{m}\) |
Ke |
|
\(\dot{m}\) |
Fluid mass flow rate |
\(\mathrm{kg} / \mathrm{s}\) |
Q |
|
\(M\) |
Valve mass |
\(\mathrm{kg}\) |
m |
|
\(P_{\mathrm{i}}\) |
Fluid pressure at the inlet |
\(\mathrm{Pa}\) |
C1.P |
|
\(P_{\mathrm{o}}\) |
Fluid pressure at the outlet |
\(\mathrm{Pa}\) |
C2.P |
|
\(v\) |
Clapper velocity |
\(\mathrm{m} / \mathrm{s}\) |
v |
|
\(z\) |
Clapper position |
\(\mathrm{m}\) |
z |
|
\(z_{\min }\) |
Clapper minimum position (valve fully closed) |
\(\mathrm{m}\) |
z_min |
|
\(z_{\max }\) |
Clapper maximum position (valve fully open) |
\(\mathrm{m}\) |
z_max |
|
\(\delta\) |
Difference between the free spring length and the spring length when the valve is closed |
\(\mathrm{m}\) |
- |
|
\(\Delta P\) |
Pressure loss of the fluid between the valve inlet and outlet |
\(\mathrm{Pa}\) |
\(P_{\mathrm{i}}-P_{\mathrm{o}}\) |
deltaP |
\(\rho\) |
Fluid density |
\(\mathrm{kg} / \mathrm{m}^{3}\) |
rho |
|
\(\rho_{\text {water, } 60^{\circ} \mathrm{F}}\) |
Density of water at \(60^{\circ} \mathrm{F}\left(15.5556^{\circ} \mathrm{C}\right) .\) |
\(\mathrm{kg} / \mathrm{m}^{3}\) |
rho60F |
|
\(\Omega\) |
Valve position |
\(-\) |
Ouv |
Governing equations#
Static momentum balance equation#
Validity domain:
\(\forall \dot{m}\) and \(C_{\mathrm{v}} \geq 0\). For \(C_{\mathrm{v}}=0, \Delta P\) must be defined.
Mathematical formulation:
Comments:
This equation is the same as the control valve \(C_{\mathrm{v}}=f_{v}(\Omega)\) where \(f_{v}\) is the valve characteristic. It is assumed that \(\Omega=\frac{z-z_{\min }}{z_{\max }-z_{\min }}\).
Clapper equation#
Validity domain:
\( z_{\min} \leq z \leq z_{\max} \)
Mathematical formulation:
Comments:
The velocity and acceleration are set to zero when the clapper hits the mechanical stops. The equal sign is replaced by \(\leq\) or \(\geq\) in the transition conditions \(z=z_{\min }\) and \(z=z_{\max }\) because equal signs are not recognized by solvers to compare real values.
References#
El Hefni, Baligh and Bouskela, Daniel (2019). Modeling and Simulation of Thermal Power Plants with ThermoSysPro, sect. 13.1. Springer Nature Switzerland AG.